03 · Estimation · Simulation
Radar Interceptor
Radar target tracking and missile interception under uncertainty.
Recorded from the running project
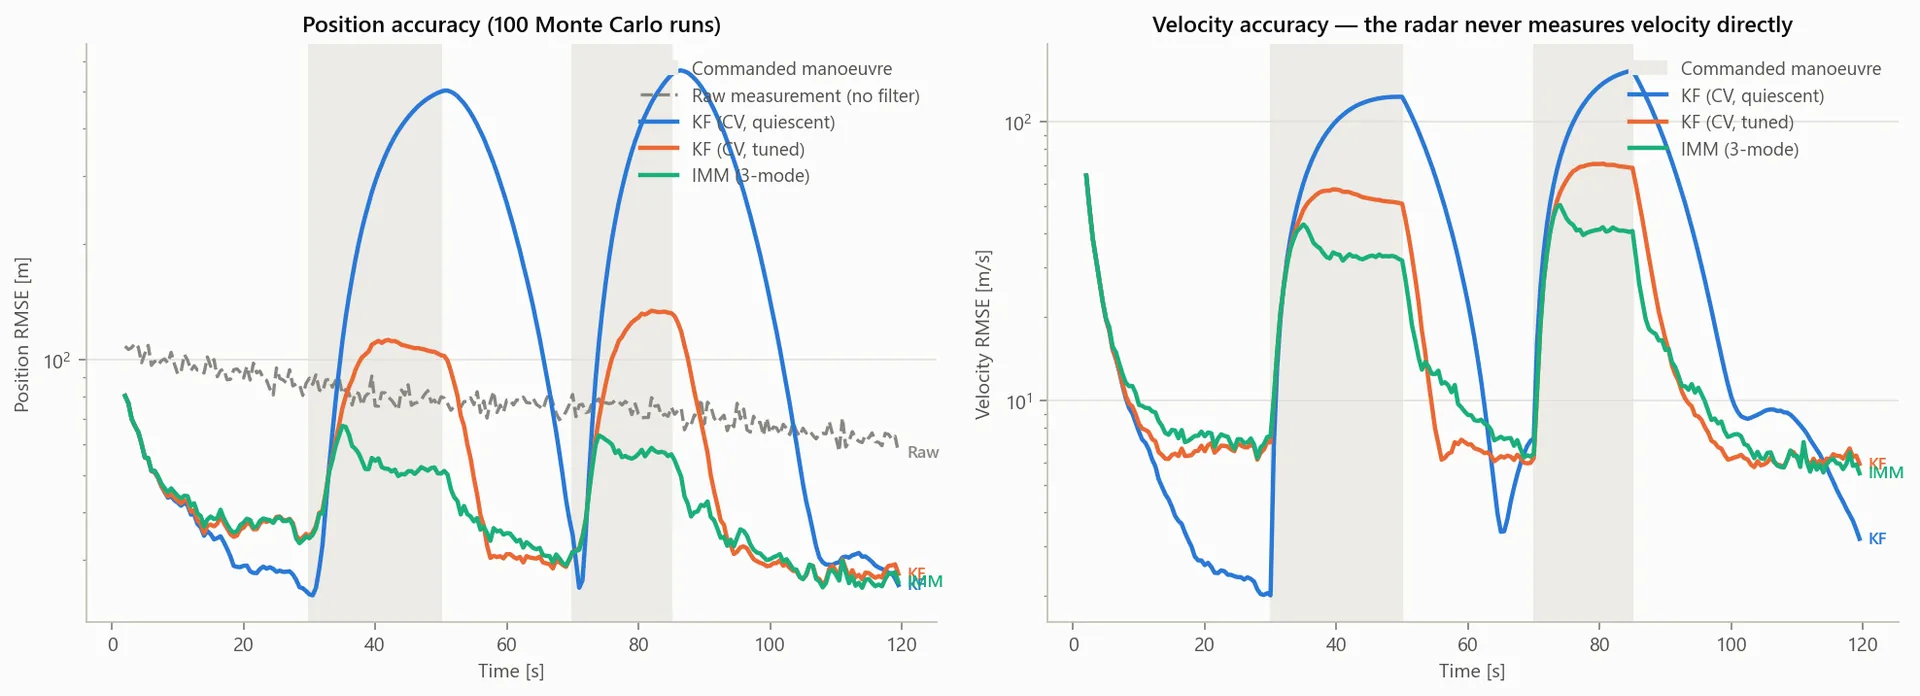
Differential-equations coursework taken further: noisy radar returns are filtered with a Kalman filter and a three-mode IMM estimator, tested across Monte Carlo runs, and shown in an interactive 3D demo that walks through the equations as they are used.
What I built
- 01
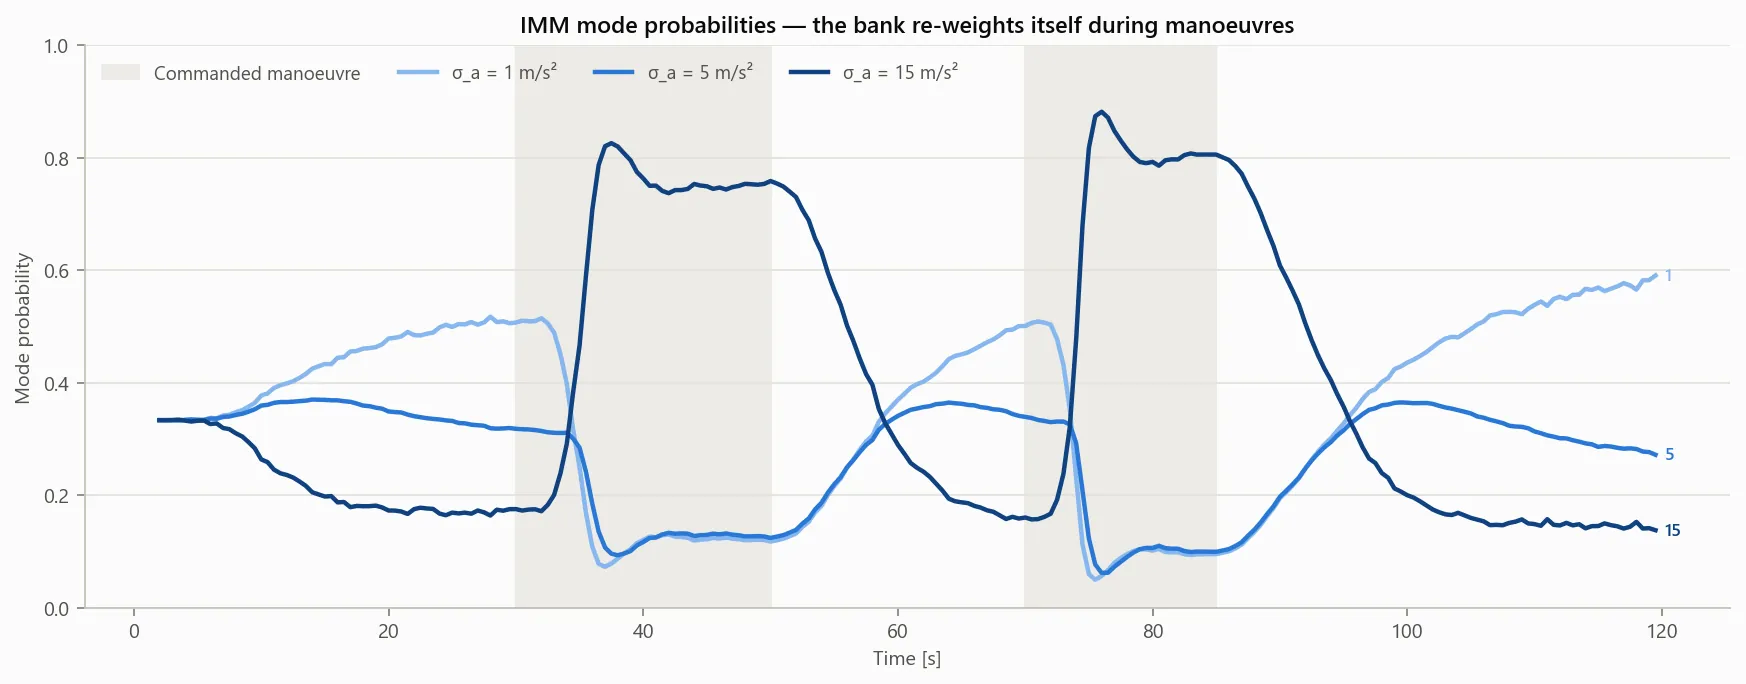
A constant-velocity Kalman filter and a three-mode Interacting Multiple Model estimator that re-weights itself during manoeuvres.
- 02
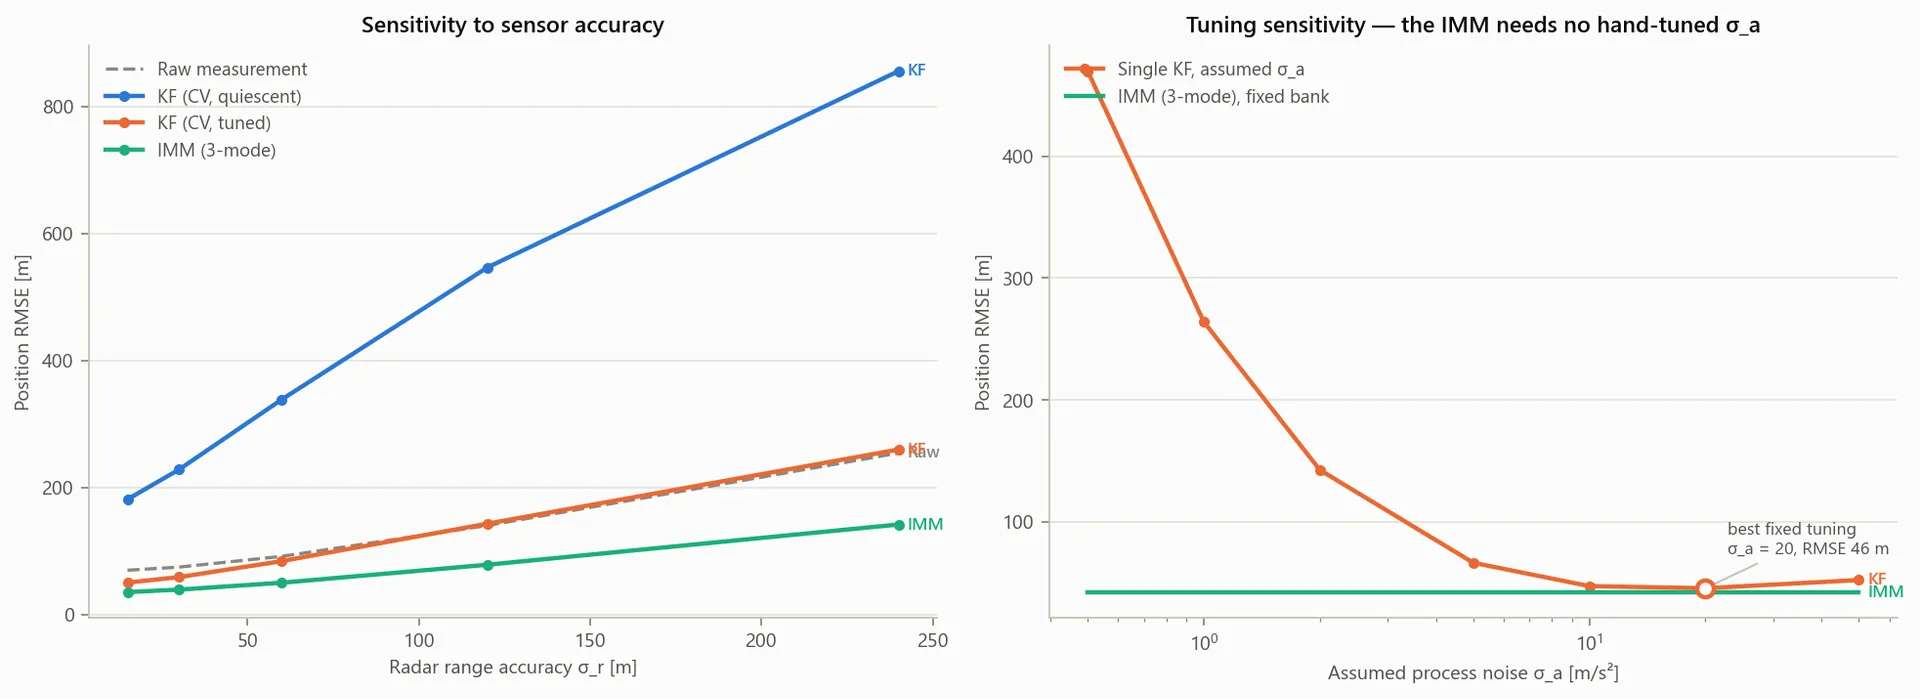
Monte Carlo experiments with filter-consistency checks (NEES/NIS), sensor-noise and tuning sweeps.
- 03
An interactive Three.js radar scene with live metrics and the equation behind each step.
- 04
A regression test over Monte Carlo runs, wired into continuous integration, plus written theory documentation.
Evidence